fullseye
tb_lf_epi_slope — 2D typed op
- データ種:
lightfield→image - 呼び出し:
fullseye.apply(img, "tb_lf_epi_slope", a=0.5, b=0.5)(2-D は 1 画像 + 2 スカラつまみa,b∈[0,1]のモデル)
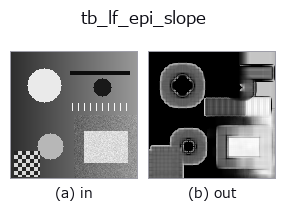
図は合成の入力 128×128 で実際に走らせた出力。左が入力、右が出力。点群は上から見た散布(明るさ = z)、1-D 列は折れ線、体積は z 方向の最大値投影、動画は中央フレーム、複素画像は振幅、絵にならない返り値は値そのもの。
つまみ a は出力を変えない(実測: 0.1 / 0.5 / 0.9 で同一)。
つまみ b は出力を変えない(実測: 0.1 / 0.5 / 0.9 で同一)。
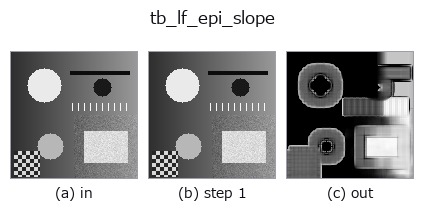
段階(前置きの op → この op。左から順):
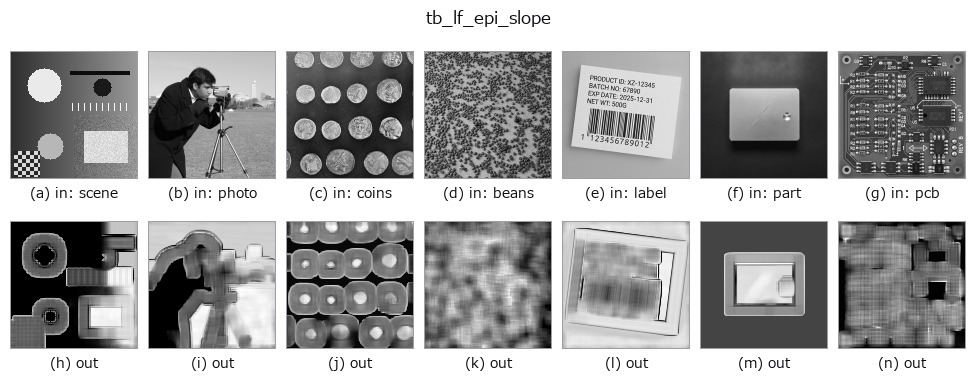
別の画像でも(合成シーン / 写真 / 硬貨。上段が入力、下段がその出力。つまみは既定):
使い方
Per-pixel slope from the EPI line orientation (structure tensor, one pass).
A scene point traces a straight line in the epipolar-plane image
(:func:lf_epi), so along that line the intensity is constant:
E_u + s * E_x = 0. Accumulating that constraint over the whole angular
grid and a window x window spatial neighbourhood gives the closed-form
least-squares slope s = -(J_ux + J_vy) / (J_xx + J_yy) with
J_ab = sum(E_a * E_b) — one pass over the light field, no sweep, both
the horizontal and vertical EPI directions pooled.
This estimator is biased, and the bias is the reason to also run
:func:lf_depth_from_focus. It is ordinary (not total) least squares on
finite differences, so it needs the EPI line to advance less than roughly
one texture correlation length per view. Measured 2026-09-01 on
5x5x64x64 synthetic fields, median over the interior: with texture
sigma = 1.5 px, true +1.00 -> +1.0004, +0.50 -> +0.5285,
+1.50 -> +1.3018, +2.00 -> +1.4614; with sigma = 5.0 px the same
slopes give +1.0003, +0.5029, +1.4827, +1.9482. Integer
slopes on a wrapped field come back within 4e-4 and s = 0 is exact;
|s| > 1 is under-estimated, by 27% at s = 2 on the roughest texture.
Use it as a fast dense initialiser, not as the final word.
Returns (slope_map, energy): the (H, W) slope map and the (H, W)
gradient energy J_xx + J_yy that was the denominator. Pixels whose
energy is below min_energy have no measurable parallax (a flat patch
of sky); their slope is set to 0 and their energy reported as-is, so you
threshold on energy instead of being handed a plausible-looking number
divided by ~0.
Raises ValueError: lf not a valid light field, an angular/spatial
shape where neither EPI direction carries information (the horizontal EPI
needs U >= 2 and W >= 2, the vertical needs V >= 2 and
H >= 2), an even or non-positive window, a non-positive min_energy.
Typed bridge of the lightfield op lf_epi_slope into the 2-D evolution registry: the same implementation, called under the op(v, a, b) convention. This op has no tunable parameter; a and b are unused.
参考(サンプルデータ・文献)
- サンプルデータ カタログ(DL URL / ライセンス) — 2-D は skimage.data(BSD/public)+ 合成、3-D は実データ源(Stanford/PDS 等)の DL URL。
- 演算子の来歴・参考文献 — この op 族の元になった研究/手法の出典。
Studio で試す
下のプログラムは実際に走ることを確かめてある(図と同じ入力)。Studio のヘルプではこのブロックがボタンになり、その場で読み込んで実行できる。
img_to_lightfield 0.50 0.50
tb_lf_epi_slope 0.50 0.50
実行できる例(この op を実際に呼ぶ検証済みサンプル)
次の例は元の台帳 op lf_epi_slope を呼ぶもの。この橋渡し op は同じ実装を fn(v, a, b) 規約に合わせただけなので、挙動はそのまま当てはまる(呼び出し形だけ違う)。
- lightfield_depth —
py -3.11 examples/lightfield_depth.py - poc_lightfield_depth —
py -3.11 examples/poc_lightfield_depth.py
型が繋がる次の op(image を入力に取れる)
identity · gaussian · mean_box · mean_box_wh · bilateral · kuwahara · unsharp · median
同カテゴリ(typed)
tb_points_to_voxel · tb_estimate_point_normals · tb_iss_keypoints · tb_project_points · tb_render_point_depth · tb_points_render · tb_statistical_outlier_removal · tb_radius_outlier_removal
Provenance: ops.py — 2D operator registry. この per-op ノートは tools/opdocs.py md が自動生成(手編集しない)。
© 2026 Kazufumi Furuse — Fullseye operator documentation. Licensed under Apache-2.0.