fullseye
tb_fly_lgmd_eta — 2D typed op
- データ種:
signal→signal - 呼び出し:
fullseye.apply(img, "tb_fly_lgmd_eta", a=0.5, b=0.5)(2-D は 1 画像 + 2 スカラつまみa,b∈[0,1]のモデル)
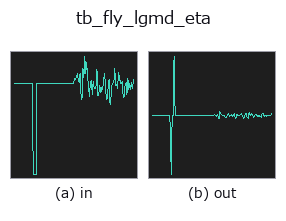
図は合成の入力 128×128 で実際に走らせた出力。左が入力、右が出力。点群は上から見た散布(明るさ = z)、1-D 列は折れ線、体積は z 方向の最大値投影、動画は中央フレーム、複素画像は振幅、絵にならない返り値は値そのもの。
つまみ a を振る(0.1 / 0.5 / 0.9、もう一方は既定):
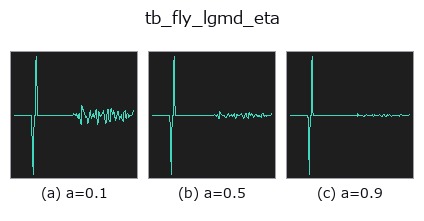
つまみ b は出力を変えない(実測: 0.1 / 0.5 / 0.9 で同一)。
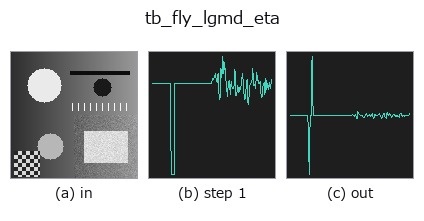
段階(前置きの op → この op。左から順):
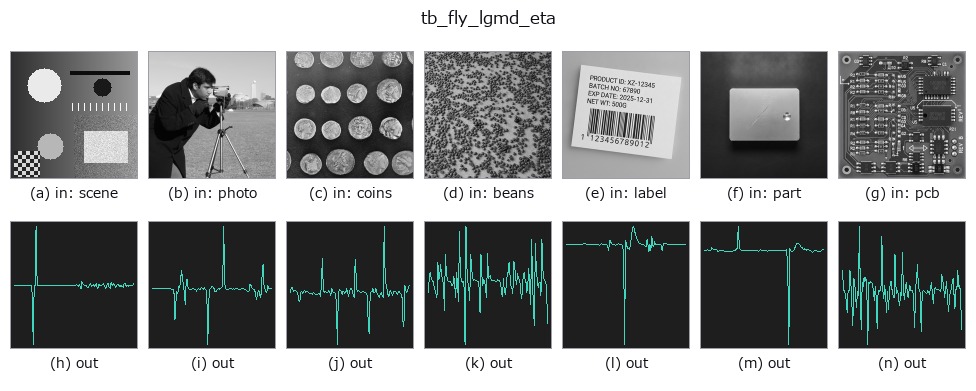
別の画像でも(合成シーン / 写真 / 硬貨。上段が入力、下段がその出力。つまみは既定):
使い方
LGMD/eta looming response from an expanding subtended angle.
The multiplicative looming model::
eta(t) = theta'(t - delay) * exp(-alpha * theta(t - delay))
where theta_signal is the object’s full subtended angle over time, in radians. The product of the angular expansion rate and an exponentially decaying gain gives a response that peaks a fixed time before collision.
theta_signal: the full subtended angle per sample, radians. dt_s: the sample interval, seconds. alpha: the gain-decay constant. delay_s: a fixed neural delay, seconds.
Returns a 1-D float64 array eta(t) of the same length.
Ground truth: for an object of half-size l approaching at speed |v|,
eta peaks at a time-to-contact of alpha*l/|v| - delay_s (Gabbiani et
al. Eq. 5), where the subtended angle is exactly 2*atan(1/alpha) (Eq. 6;
24.0 degrees for alpha = 4.7) — both pinned in the tests.
Raises ValueError: a non-1-D / empty / too-short (< 3) / non-finite
theta_signal, a signal over :data:MAX_SIGNAL_POINTS, a non-positive dt_s
/ alpha, and a negative delay_s.
Typed bridge of the flyvision op fly_lgmd_eta into the 2-D evolution registry: the same implementation, called under the op(v, a, b) convention. a drives alpha (default 4.7); b is unused.
参考(サンプルデータ・文献)
- サンプルデータ カタログ(DL URL / ライセンス) — 2-D は skimage.data(BSD/public)+ 合成、3-D は実データ源(Stanford/PDS 等)の DL URL。
- 演算子の来歴・参考文献 — この op 族の元になった研究/手法の出典。
Studio で試す
下のプログラムは実際に走ることを確かめてある(図と同じ入力)。Studio のヘルプではこのブロックがボタンになり、その場で読み込んで実行できる。
img_to_signal 0.50 0.50
tb_fly_lgmd_eta 0.50 0.50
実行できる例(この op を実際に呼ぶ検証済みサンプル)
次の例は元の台帳 op fly_lgmd_eta を呼ぶもの。この橋渡し op は同じ実装を fn(v, a, b) 規約に合わせただけなので、挙動はそのまま当てはまる(呼び出し形だけ違う)。
- poc_fly_vision —
py -3.11 examples/poc_fly_vision.py
型が繋がる次の op(signal を入力に取れる)
identity · tb_create_funct_1d_array · tb_smooth_funct_1d_gauss · tb_smooth_funct_1d_mean · tb_derivate_funct_1d · tb_integrate_funct_1d · tb_zero_crossings_funct_1d · tb_abs_funct_1d
同カテゴリ(typed)
tb_points_to_voxel · tb_estimate_point_normals · tb_iss_keypoints · tb_project_points · tb_render_point_depth · tb_points_render · tb_statistical_outlier_removal · tb_radius_outlier_removal
Provenance: ops.py — 2D operator registry. この per-op ノートは tools/opdocs.py md が自動生成(手編集しない)。
© 2026 Kazufumi Furuse — Fullseye operator documentation. Licensed under Apache-2.0.