fullseye
tb_dtof_depth — 2D typed op
- データ種:
counts→feature - 呼び出し:
fullseye.apply(img, "tb_dtof_depth", a=0.5, b=0.5)(2-D は 1 画像 + 2 スカラつまみa,b∈[0,1]のモデル)
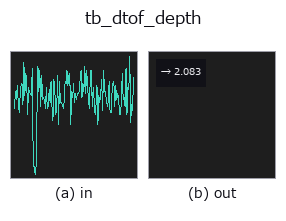
図は合成の入力 128×128 で実際に走らせた出力。左が入力、右が出力。点群は上から見た散布(明るさ = z)、1-D 列は折れ線、体積は z 方向の最大値投影、動画は中央フレーム、複素画像は振幅、絵にならない返り値は値そのもの。
つまみ a を振る(0.1 / 0.5 / 0.9、もう一方は既定):
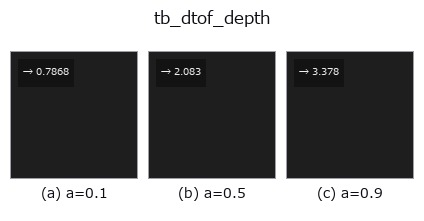
つまみ b は出力を変えない(実測: 0.1 / 0.5 / 0.9 で同一)。
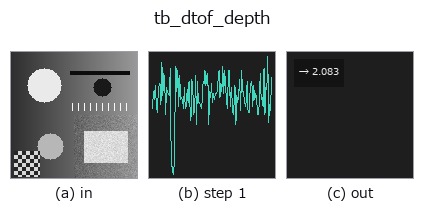
段階(前置きの op → この op。左から順):
使い方
Distance from a photon arrival-time histogram: d = c*t/2.
Direct time-of-flight. The light travels to the target and back, so the one-way distance is half the round-trip time times the speed of light. bin_ps is the width of one time bin (a 100 ps bin is 1.50 cm of depth).
Four estimators, from crudest to sharpest:
"peak"— the centre of the fullest bin. Quantised to the bin grid; the error is uniform in+-halfa bin (+-0.75 cmat 100 ps)."centroid"— the first moment of the whole histogram. Exact for a symmetric pulse with no background, and badly biased toward the middle of the window with one — passsubtract_background=True."parabolic"— a parabola through the peak bin and its two neighbours. Sub-bin, cheap, and biased for a Gaussian pulse."gaussian"— the same parabola fitted to the log of those three samples, which is the exact vertex for a Gaussian pulse.
Measured on a noiseless simulated return at 2.4371 m (256 bins x 100 ps,
500 ps IRF), absolute error: peak 1.29 mm, centroid 4.4e-16 m,
parabolic 0.067 mm, gaussian 9.4e-9 m — three orders of magnitude
between the crudest and the sharpest.
With Poisson noise (200 signal + 200 ambient photons, seed 0) the same
four give 13.7 mm, 146.5 mm (with subtract_background=True), 8.5 mm and
8.0 mm. Two honest readings of that: once shot noise dominates the sub-bin
estimators buy about 1.6x, not three orders of magnitude, and the centroid
collapses because a median-subtracted ambient floor still leaves noise
across the whole window that drags the first moment toward the centre. Use
"gaussian" or "parabolic" on noisy data; use "centroid" only when
the background is genuinely gone.
offset_ps is a system delay to remove: t_flight = t_measured -
offset_ps, so a positive offset makes the answer closer. Returns the
distance in metres as a float.
Raises ValueError: negative, non-finite, non-1-D or all-zero hist,
a non-positive bin_ps, an unknown mode, a non-finite offset_ps, a
flat histogram in a peak-based mode (argmax would silently pick bin 0
and report the first bin’s depth), a peak in the first or last bin with a
sub-bin mode (there is no neighbour to fit to — use "peak"), a
degenerate three-sample fit, and — instead of returning a negative distance —
an offset_ps larger than the measured arrival time.
Typed bridge of the photon op dtof_depth into the 2-D evolution registry: the same implementation, called under the op(v, a, b) convention. a drives bin_ps (default 100); b is unused.
参考(サンプルデータ・文献)
- サンプルデータ カタログ(DL URL / ライセンス) — 2-D は skimage.data(BSD/public)+ 合成、3-D は実データ源(Stanford/PDS 等)の DL URL。
- 演算子の来歴・参考文献 — この op 族の元になった研究/手法の出典。
Studio で試す
下のプログラムは実際に走ることを確かめてある(図と同じ入力)。Studio のヘルプではこのブロックがボタンになり、その場で読み込んで実行できる。
img_to_counts 0.50 0.50
tb_dtof_depth 0.50 0.50
実行できる例(この op を実際に呼ぶ検証済みサンプル)
次の例は元の台帳 op dtof_depth を呼ぶもの。この橋渡し op は同じ実装を fn(v, a, b) 規約に合わせただけなので、挙動はそのまま当てはまる(呼び出し形だけ違う)。
- photon_timeresolved —
py -3.11 examples/photon_timeresolved.py - poc_dtof_ranging —
py -3.11 examples/poc_dtof_ranging.py
型が繋がる次の op(feature を入力に取れる)
同カテゴリ(typed)
tb_points_to_voxel · tb_estimate_point_normals · tb_iss_keypoints · tb_project_points · tb_render_point_depth · tb_points_render · tb_statistical_outlier_removal · tb_radius_outlier_removal
Provenance: ops.py — 2D operator registry. この per-op ノートは tools/opdocs.py md が自動生成(手編集しない)。
© 2026 Kazufumi Furuse — Fullseye operator documentation. Licensed under Apache-2.0.