fullseye
tb_cplx_cr_residual — 2D typed op
- データ種:
cimage→feature - 呼び出し:
fullseye.apply(img, "tb_cplx_cr_residual", a=0.5, b=0.5)(2-D は 1 画像 + 2 スカラつまみa,b∈[0,1]のモデル)
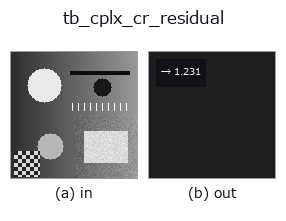
図は合成の入力 128×128 で実際に走らせた出力。左が入力、右が出力。点群は上から見た散布(明るさ = z)、1-D 列は折れ線、体積は z 方向の最大値投影、動画は中央フレーム、複素画像は振幅、絵にならない返り値は値そのもの。
つまみ a は出力を変えない(実測: 0.1 / 0.5 / 0.9 で同一)。
つまみ b は出力を変えない(実測: 0.1 / 0.5 / 0.9 で同一)。
段階(前置きの op → この op。左から順):
使い方
Cauchy-Riemann residual of a sampled complex field — “is this field holomorphic?” as a number.
With ``f = u + i v`` sampled on a uniform grid, holomorphy means
``u_x = v_y`` and ``u_y = -v_x`` (Cauchy-Riemann). This returns the
**relative** residual ``max(|u_x - v_y|, |u_y + v_x|) / max|grad|``
(central differences, ``numpy.gradient``): ``0`` = the samples satisfy CR to
the discretisation limit, ``2`` = the field is the conjugate of a
holomorphic one (``conj(z)`` gives exactly 2), values in between = partly
analytic or noisy.

**Grid convention (it decides the sign of the answer)**: ``f[i, j]`` is the
field at ``z = x0 + j*spacing + i*spacing*1j`` — rows index the *increasing
imaginary* axis, columns the real axis. Image arrays usually run rows
*downward*; feeding one directly measures the conjugate field, whose
residual is ``2``, not ``0``. Flip rows (``f[::-1]``) to use image data.

Discretisation, honestly: central differences are exact for polynomials of
degree <= 2, so ``f = z**2`` returns exactly 0; for higher order the
residual floors at ``O(h^2 * |f'''|)`` (measured: ``f = z**3`` on a
``[-1,1]^2`` grid returns 1.7e-3 at ``h`` and 4.2e-4 at
``h/2`` — a factor 4.00, the expected second order). Read a
small value as "consistent with holomorphic at this resolution", never as
proof.

A constant field returns ``0.0`` (it is holomorphic; the ``0/0`` of the
normalisation is resolved by that limit, and stated here rather than left
to numpy).

**Raises** ``ValueError``: not a 2-D array, either dimension below 3 (no
central difference exists), non-finite/masked input, over-cap size,
non-finite or non-positive *spacing*.

HALCON: no operator (``derivate_gauss`` supplies the real-valued
derivatives one would build this from).
Typed bridge of the math op cplx_cr_residual into the 2-D evolution registry: the same implementation, called under the op(v, a, b) convention. a drives spacing (default 1); b is unused.
参考(サンプルデータ・文献)
- サンプルデータ カタログ(DL URL / ライセンス) — 2-D は skimage.data(BSD/public)+ 合成、3-D は実データ源(Stanford/PDS 等)の DL URL。
- 演算子の来歴・参考文献 — この op 族の元になった研究/手法の出典。
Studio で試す
下のプログラムは実際に走ることを確かめてある(図と同じ入力)。Studio のヘルプではこのブロックがボタンになり、その場で読み込んで実行できる。
img_to_cimage 0.50 0.50
tb_cplx_cr_residual 0.50 0.50
実行できる例(この op を実際に呼ぶ検証済みサンプル)
次の例は元の台帳 op cplx_cr_residual を呼ぶもの。この橋渡し op は同じ実装を fn(v, a, b) 規約に合わせただけなので、挙動はそのまま当てはまる(呼び出し形だけ違う)。
- math_complex —
py -3.11 examples/math_complex.py
型が繋がる次の op(feature を入力に取れる)
同カテゴリ(typed)
tb_points_to_voxel · tb_estimate_point_normals · tb_iss_keypoints · tb_project_points · tb_render_point_depth · tb_statistical_outlier_removal · tb_radius_outlier_removal · tb_voxel_grid_downsample
Provenance: ops.py — 2D operator registry. この per-op ノートは tools/opdocs.py md が自動生成(手編集しない)。
© 2026 Kazufumi Furuse — Fullseye operator documentation. Licensed under Apache-2.0.